 |
Flexiv TDK APIs 1.7
|
Loading...
Searching...
No Matches
|
Flexiv TDK APIs 1.7
|
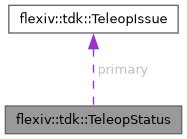
Snapshot of teleoperation health for one robot pair. More...
#include <data.hpp>
Public Attributes | |
| bool | initialized = false |
| bool | started = false |
| bool | engaged = false |
| bool | stopped = true |
| bool | fault = false |
| bool | motion_restricted = false |
| double | latency_ms = 0.0 |
| double | latency_threshold_ms = 0.0 |
| TeleopIssue | primary |
| std::vector< TeleopIssue > | issues |
[primary] is the issue the host should show first: the highest-level active issue, or the last significant event if nothing is active. [issues] lists every condition that is active right now.
| bool flexiv::tdk::TeleopStatus::engaged = false |
False if the operator has not engaged, or if the controller force-disengaged (high latency, disconnect, or clock mismatch). Check [issues] / [primary] for CLOCK_MISMATCH when [latency_ms] is negative.
| bool flexiv::tdk::TeleopStatus::fault = false |
LAN: true if either robot in the pair is in fault state. WAN: true if the local robot is.
| bool flexiv::tdk::TeleopStatus::initialized = false |
True if Init() or InitWithIdx() has completed for this robot pair.
| std::vector<TeleopIssue> flexiv::tdk::TeleopStatus::issues |
All currently active issues. Empty when the system is healthy.
| double flexiv::tdk::TeleopStatus::latency_ms = 0.0 |
Estimated one-way message latency in milliseconds. WAN only; 0 on LAN. Negative means clock mismatch. A very large value means not connected.
| double flexiv::tdk::TeleopStatus::latency_threshold_ms = 0.0 |
Configured latency threshold in milliseconds. WAN only.
| bool flexiv::tdk::TeleopStatus::motion_restricted = false |
True if the robot currently holds pose to avoid a limit or singularity.
| TeleopIssue flexiv::tdk::TeleopStatus::primary |
Highest-priority issue to display. [primary.code] is NONE when nothing is wrong.
| bool flexiv::tdk::TeleopStatus::started = false |
True if the teleoperation control loop has been started.
| bool flexiv::tdk::TeleopStatus::stopped = true |
True if the teleoperation control loop is not running. Always the inverse of [started].
 1.15.0