Header file containing various constant expressions, data structs, and enums.
More...
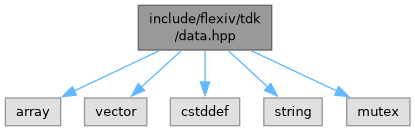
#include <array>
#include <vector>
#include <cstddef>
#include <string>
#include <mutex>
Go to the source code of this file.
|
| struct | flexiv::tdk::NetworkCfgStd |
| | TCP Server and Client Configuration TDK Standard Edition. In a teleoperation-over-WAN setup, there are one robot + one edge device on each side of the teleoperation. One edge device needs to function as a TCP server while the other device functions as a TCP client. It does not matter which side is configured as TCP server or client. However, while the edge device for TCP client doesn't need any additional configuration other than connecting to the Internet, the TCP server needs to complete the following additional steps: More...
|
| struct | flexiv::tdk::NetworkCfgPro |
| | Network configuration for TDK Professional Edition (credential file from TDK Server). More...
|
| struct | flexiv::tdk::MotionControlCmds |
| | Motion control command struct for general device-robot teleop. More...
|
| struct | flexiv::tdk::AxisLock |
| | Data for locking axis, including reference frame and axis to be locked for transparent cartesian teleop. Coordinate type options are: COORD_TCP ("TCP") for TCP frame and COORD_WORLD ("WORLD") for WORLD frame. More...
|
| struct | flexiv::tdk::TeleopIssue |
| | One restriction or interruption that the operator should understand. More...
|
| struct | flexiv::tdk::TeleopStatus |
| | Snapshot of teleoperation health for one robot pair. More...
|
|
| enum | flexiv::tdk::Role { flexiv::tdk::UNKNOWN = 0
, flexiv::tdk::LAN_TELEOP
, flexiv::tdk::WAN_TELEOP_LEADER
, flexiv::tdk::WAN_TELEOP_FOLLOWER
} |
| | Roles of participants in transparent cartesian teleop. More...
|
| enum | flexiv::tdk::CoordType { flexiv::tdk::COORD_UNKNOWN = 0
, flexiv::tdk::COORD_TCP
, flexiv::tdk::COORD_WORLD
} |
| | Reference coordinate that the axis to be locked used by transparent cartesian teleop. More...
|
| enum class | flexiv::tdk::ZeroFTSensor { Enable
, Disable
} |
| | Sensor calibration options. More...
|
| enum class | flexiv::tdk::TeleopIssueCode {
NONE = 0
, JOINT_LIMIT
, SINGULARITY
, HIGH_JOINT_VELOCITY
,
HIGH_LATENCY
, NETWORK_DISCONNECTED
, CLOCK_MISMATCH
, ROBOT_FAULT
,
ROBOT_NOT_OPERATIONAL
, CONTROL_MODE_MISMATCH
} |
| | Issue code and possible reasons for a teleoperation restriction or interruption. More...
|
| enum class | flexiv::tdk::TeleopIssueLevel { INFO = 0
, WARNING
, ERROR
} |
| | How urgently a teleop issue should be presented to the operator. More...
|
| enum class | flexiv::tdk::TeleopIssueSide { NONE = 0
, LEADER
, FOLLOWER
, NETWORK
} |
| | Which participant the issue belongs to. More...
|
- Copyright
- Copyright (C) 2016-2026 Flexiv Ltd. All Rights Reserved.
Definition in file data.hpp.
◆ CoordType
| Enumerator |
|---|
| COORD_UNKNOWN | Unknown coordinate.
|
| COORD_TCP | TCP coordinate of local robot.
|
| COORD_WORLD | WORLD coordinate of local robot.
|
Definition at line 219 of file data.hpp.
◆ Role
◆ TeleopIssueCode
- Note
- Host applications should switch on this code for localization. The English title/description/suggestion in TeleopIssue are defaults for logs and simple UIs.
| Enumerator |
|---|
| NONE | No issue.
|
| JOINT_LIMIT | A joint is near its position limit.
|
| SINGULARITY | Arm is near a kinematic singularity.
|
| HIGH_JOINT_VELOCITY | Joint velocity is close to the safety limit.
|
| HIGH_LATENCY | Network latency exceeded the configured threshold; teleop is force-disengaged.
|
| NETWORK_DISCONNECTED | Connection to the peer is not established.
|
| CLOCK_MISMATCH | Clocks disagree (negative latency); teleop is force-disengaged.
|
| ROBOT_FAULT | Robot is in fault state.
|
| ROBOT_NOT_OPERATIONAL | Robot is not operational (E-Stop, disabled, or link lost).
|
| CONTROL_MODE_MISMATCH | Robot left real-time Cartesian motion-force mode.
|
- Examples
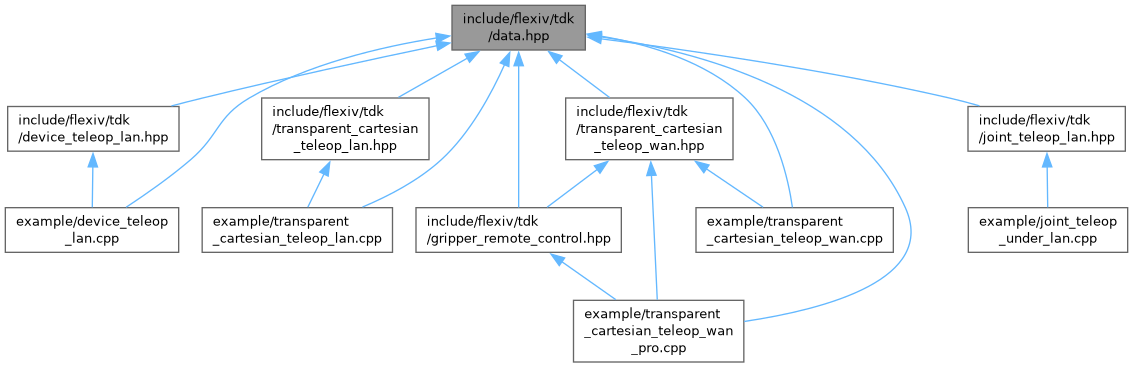
- transparent_cartesian_teleop_wan.cpp, and transparent_cartesian_teleop_wan_pro.cpp.
Definition at line 285 of file data.hpp.
◆ TeleopIssueLevel
| Enumerator |
|---|
| INFO | Advisory. Motion is still possible.
|
| WARNING | Motion is restricted.
|
| ERROR | Teleop was disengaged, stopped, or the robot needs recovery.
|
Definition at line 308 of file data.hpp.
◆ TeleopIssueSide
| Enumerator |
|---|
| LEADER | Leader / operator-side robot.
|
| FOLLOWER | Follower / remote-environment robot.
|
| NETWORK | Link between the two sides, not a specific robot.
|
Definition at line 321 of file data.hpp.
◆ ZeroFTSensor
◆ GetTeleopIssueLevel()
◆ kCartDoF
| size_t flexiv::tdk::kCartDoF = 6 |
|
constexpr |
Cartesian-space degrees of freedom
Definition at line 18 of file data.hpp.
◆ kIOPorts
| size_t flexiv::tdk::kIOPorts = 18 |
|
constexpr |
Number of digital IO ports (16 on control box + 2 inside the wrist connector)
Definition at line 24 of file data.hpp.
◆ kMaxRobotPairsNum
| size_t flexiv::tdk::kMaxRobotPairsNum = 2 |
|
constexpr |
Max robot pairs
Definition at line 30 of file data.hpp.
◆ kMaxWrenchFeedbackScale
| double flexiv::tdk::kMaxWrenchFeedbackScale = 3 |
|
constexpr |
Max wrench feedback scaling factor for transparent teleop
Definition at line 27 of file data.hpp.
◆ kPoseSize
| size_t flexiv::tdk::kPoseSize = 7 |
|
constexpr |
Size of pose array (3 position + 4 quaternion)
Definition at line 21 of file data.hpp.
 1.15.0