 |
Flexiv TDK APIs 2.1
|
Loading...
Searching...
No Matches
|
Flexiv TDK APIs 2.1
|
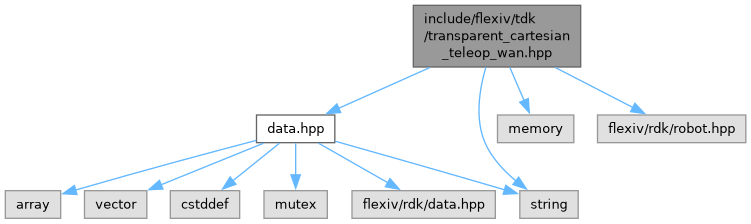
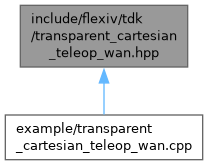
Go to the source code of this file.
Classes | |
| class | flexiv::tdk::TransparentCartesianTeleopWAN |
| Teleoperation control interface that represents leader or follower robots in transparent teleoperation over WAN. More... | |
Definition in file transparent_cartesian_teleop_wan.hpp.
 1.15.0