Header file containing various constant expressions, data structs, and enums.
More...
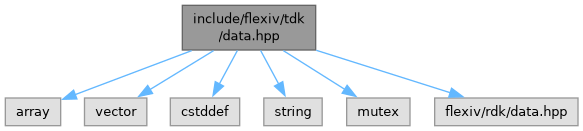
#include <array>
#include <vector>
#include <cstddef>
#include <string>
#include <mutex>
#include <flexiv/rdk/data.hpp>
Go to the source code of this file.
|
| struct | flexiv::tdk::NetworkCfgStd |
| | TCP Server and Client Configuration TDK Standard Edition. In TDK standard edition, there are one robot + one edge device on each side of the teleoperation. One edge device needs to function as a TCP server while the other device functions as a TCP client. It does not matter which side is configured as TCP server or client. However, while the edge device for TCP client doesn't need any additional configuration other than connecting to the Internet, the TCP server needs to complete the following additional steps: More...
|
| struct | flexiv::tdk::MotionControlCmds |
| | Motion control command struct for general device-robot teleop. More...
|
| struct | flexiv::tdk::AxisLock |
| | Data for locking axis, including reference frame and axis to be locked for transparent cartesian teleop. Coordinate type options are: "COORD_TCP" for TCP frame and "COORD_WORLD" for WORLD frame. More...
|
- Copyright
- Copyright (C) 2016-2026 Flexiv Ltd. All Rights Reserved.
Definition in file data.hpp.
◆ CoordType
| Enumerator |
|---|
| COORD_TCP |
Unknown coordinate
|
| COORD_WORLD |
TCP coordinate of local robot
WORLD coordinate of local robot
|
Definition at line 193 of file data.hpp.
◆ Role
| Enumerator |
|---|
| LAN_TELEOP |
Unknown role.
|
| WAN_TELEOP_LEADER |
Teleoperation in LAN.
|
| WAN_TELEOP_FOLLOWER |
The leader robot operated by a human during teleoperation over WAN.
|
- Examples
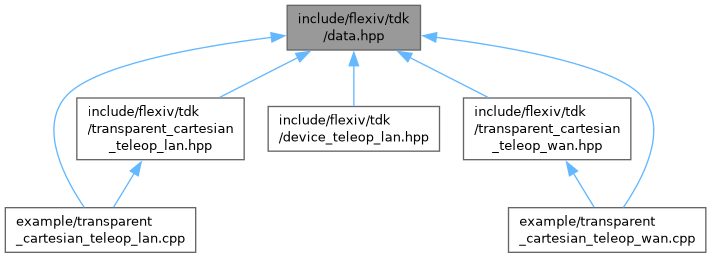
- transparent_cartesian_teleop_wan.cpp.
Definition at line 94 of file data.hpp.
◆ ZeroFTSensor
◆ kCartDoF
| size_t flexiv::tdk::kCartDoF = 6 |
|
constexpr |
Cartesian-space degrees of freedom
Definition at line 19 of file data.hpp.
◆ kIOPorts
| size_t flexiv::tdk::kIOPorts = 16 + 2 * 2 |
|
constexpr |
Number of digital IO ports (16 on control box + 2 inside the wrist connector * 2 max wrists )
Definition at line 25 of file data.hpp.
◆ kMaxRobotPairsNum
| size_t flexiv::tdk::kMaxRobotPairsNum = 2 |
|
constexpr |
Max robot pairs
Definition at line 31 of file data.hpp.
◆ kMaxWrenchFeedbackScale
| double flexiv::tdk::kMaxWrenchFeedbackScale = 3 |
|
constexpr |
Max wrench feedback scaling factor for transparent teleop under LAN
Definition at line 28 of file data.hpp.
◆ kPoseSize
| size_t flexiv::tdk::kPoseSize = 7 |
|
constexpr |
Size of pose array (3 position + 4 quaternion)
Definition at line 22 of file data.hpp.
 1.15.0