 |
Flexiv TDK APIs 1.7
|
Loading...
Searching...
No Matches
|
Flexiv TDK APIs 1.7
|
#include "data.hpp"#include "transparent_cartesian_teleop_wan.hpp"#include <string>#include <memory>#include <flexiv/rdk/gripper.hpp>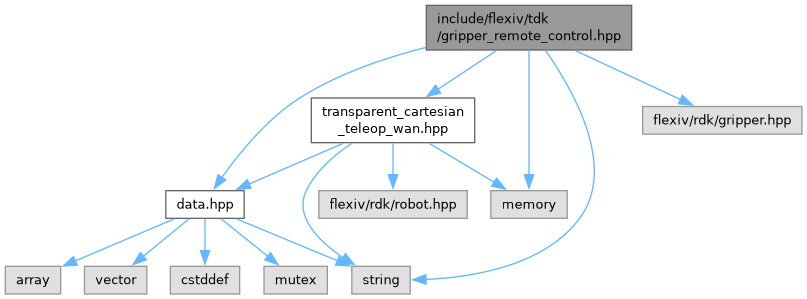
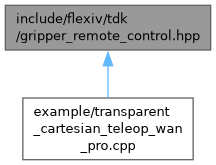
Go to the source code of this file.
Classes | |
| class | flexiv::tdk::GripperRemoteControl |
| Remote gripper control interface for the TransparentCartesianTeleopWAN teleoperation scenario. When the follower robot has a gripper installed and configured, the operator interacting with the leader robot can control the follower's gripper through this interface. More... | |
Definition in file gripper_remote_control.hpp.
 1.15.0